LLC™ software module is engineered specifically for controlling leveler and straightener applications requiring loop control — embedded within the drive controller to eliminate external control racks.
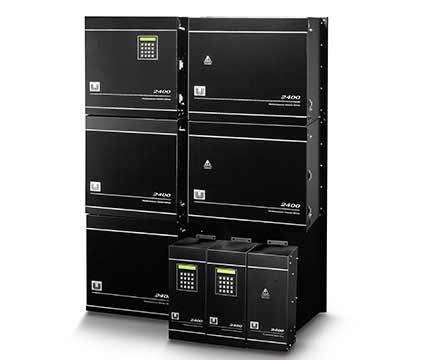
LLC™ software module is engineered specifically for controlling leveler and straightener applications requiring loop control. The program is embedded within the controller of a drive, eliminating the need for an external control rack.
When used in conjunction with a programmable controller, the drive forms a powerful automation work cell that can either stand-alone or be easily integrated with other automation cells to build a complete control system for a metal-processing line. Embedded control reduces system complexity while taking full advantage of the exceptional performance, flexibility, and ease of use of drives.
Purpose-built control features engineered for precision, flexibility, and throughput on every loop leveler application.
The loop control regulates loop depth by controlling the speed of a motor, such as a leveler or a straightener, at the entry side of a pit. Two loop modes are provided. Loop fill mode maintains the loop at a prescribed depth, filling it whenever material is removed. This mode is typically entered following thread-up to keep the loop filled while jogging or single-feeding prior to entering line run. Automatic loop mode runs the loop drive at a nearly constant velocity, varying its speed only as necessary to keep the loop within the desired operating range. Zone limiting provides the ability to keep the loop within a specific loop zone in cases where material slippage is a concern.
Precise loop regulation is achieved using encoders on the entry and exit sides of the loop to directly measure the amount of material entering and leaving the pit. Normally, these feedback devices would be a leveler or straightener motor pulse generator and a feeder motor pulse generator. The calculation is referenced to the loop eyes to compensate for any error introduced by material slippage. Continuous monitoring of loop material minimizes variations in the speed of the looping drive and helps to eliminate loop violence, roll marks, catenary slapping, and scratching. It also makes it easier for the uncoiler to maintain consistent back tension.
An automatic creep mode keeps the drive running at a very slow speed whenever the line is stopped but remains automatic. This prevents damaging the material with roll marks that result from stopping and starting a leveler or straightener. If the line is restarted before the loop reaches the bottom, the loop will resume its previous mode. The motor stops when the material reaches the full-loop light.
The control supports digital inputs for up to four loop eyes for monitoring and controlling the depth of the loop. The eyes provide an absolute reference as to the amount of material stored in the pit when an eye is crossed. An automatic referencing feature simplifies the setup of the eyes by determining the loop storage at each. The loop eyes also guard against tight- and full-loop conditions.
An external device, such as a sonic or laser sensor, can alternately be used in place of the middle loop eyes to directly measure loop depth. Feedback is supplied as an analog input that can be filtered to remove any noise or disturbance in the signal.
Loop referencing can be disabled during line thread-up or tail out to prevent the loop table of the leveler or straightener from interfering with the loop eyes or external loop-depth feedback device.
The control can be customized to a specific installation using UEdit™, a powerful Windows-based programming tool that lets users add their own ladder logic and function block programming.
A variety of input/output functions are provided for integrating the flying cutoff control with external devices. The user can select the functions required by a given system and specify their corresponding hardware or serial I/O points.
Standard I/O functions available for integrating the Loop Leveler control with external devices.
| Input | Output |
|---|---|
| motor on | motor on |
| fault reset | no fault |
| manual | serial outputs 0–15 |
| auto | motor on |
| auto | motor on |
| auto run | no fault |
| jog forward | manual |
| jog forward | auto |
| reference-request | crop |
| auto | forward limit |
| crop request | reverse limit |
| cut engaged | fire shear |
| reference switch | reference grant |
| advance mark | line too fast |
| batch reset | forward limit fault |
| part reject | part error |
| clear mark queue | detector error |
| fast stop | batch complete |
| motion enable | early warning |
| in motion | |
| forward motion | |
| reverse motion |
Talk to our engineers about the LLC™ module for your application.
We are proud to partner with some of the most respected names in manufacturing and industrial processing.